Journal
A Novel Flexible Shaft-driven Mechanism for Multidirectional Active Force Feedback in Haptic Gloves: A Preliminary Study
Daegeun Park, Hojeong Lee, Sang Ho Yoon, Sung-Uk Jung
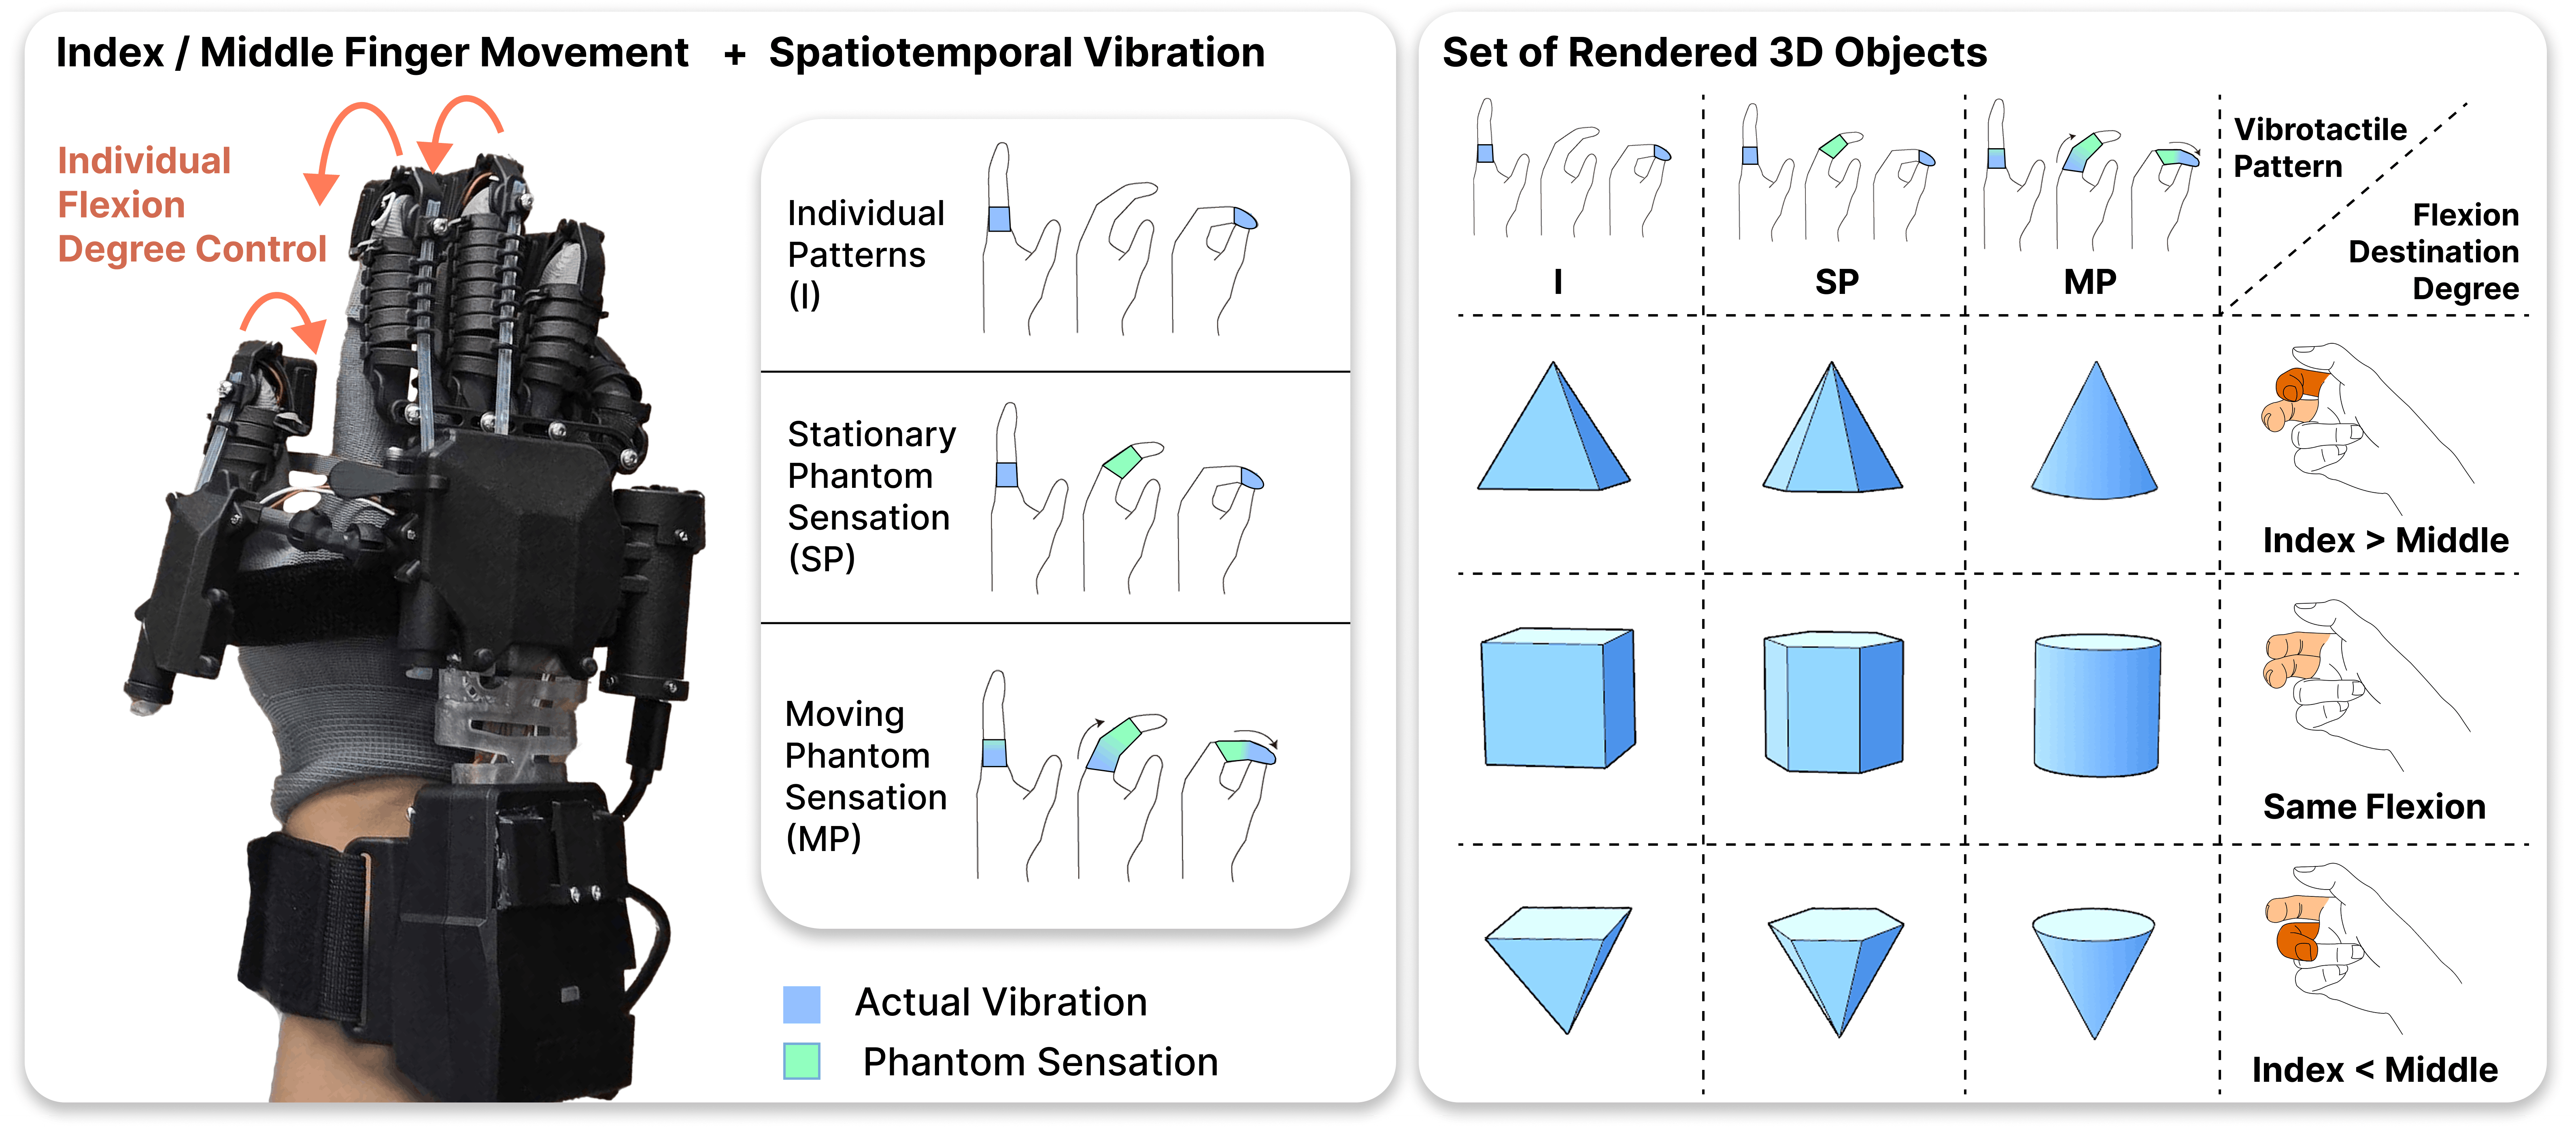
Multidirectional force feedback mechanism using flexible shaft and exoskeleton module for effective 2-DoF finger movement.
IEEE Robotics and Automation Letters (RA-L) Volume: 11, Issue: 10, October 2026